PLC & Motion Simulator
Test control logic on a simulated machine before it reaches hardware: Structured Text on a real scan cycle, or your PLC over Modbus TCP.
Product pages are in English.
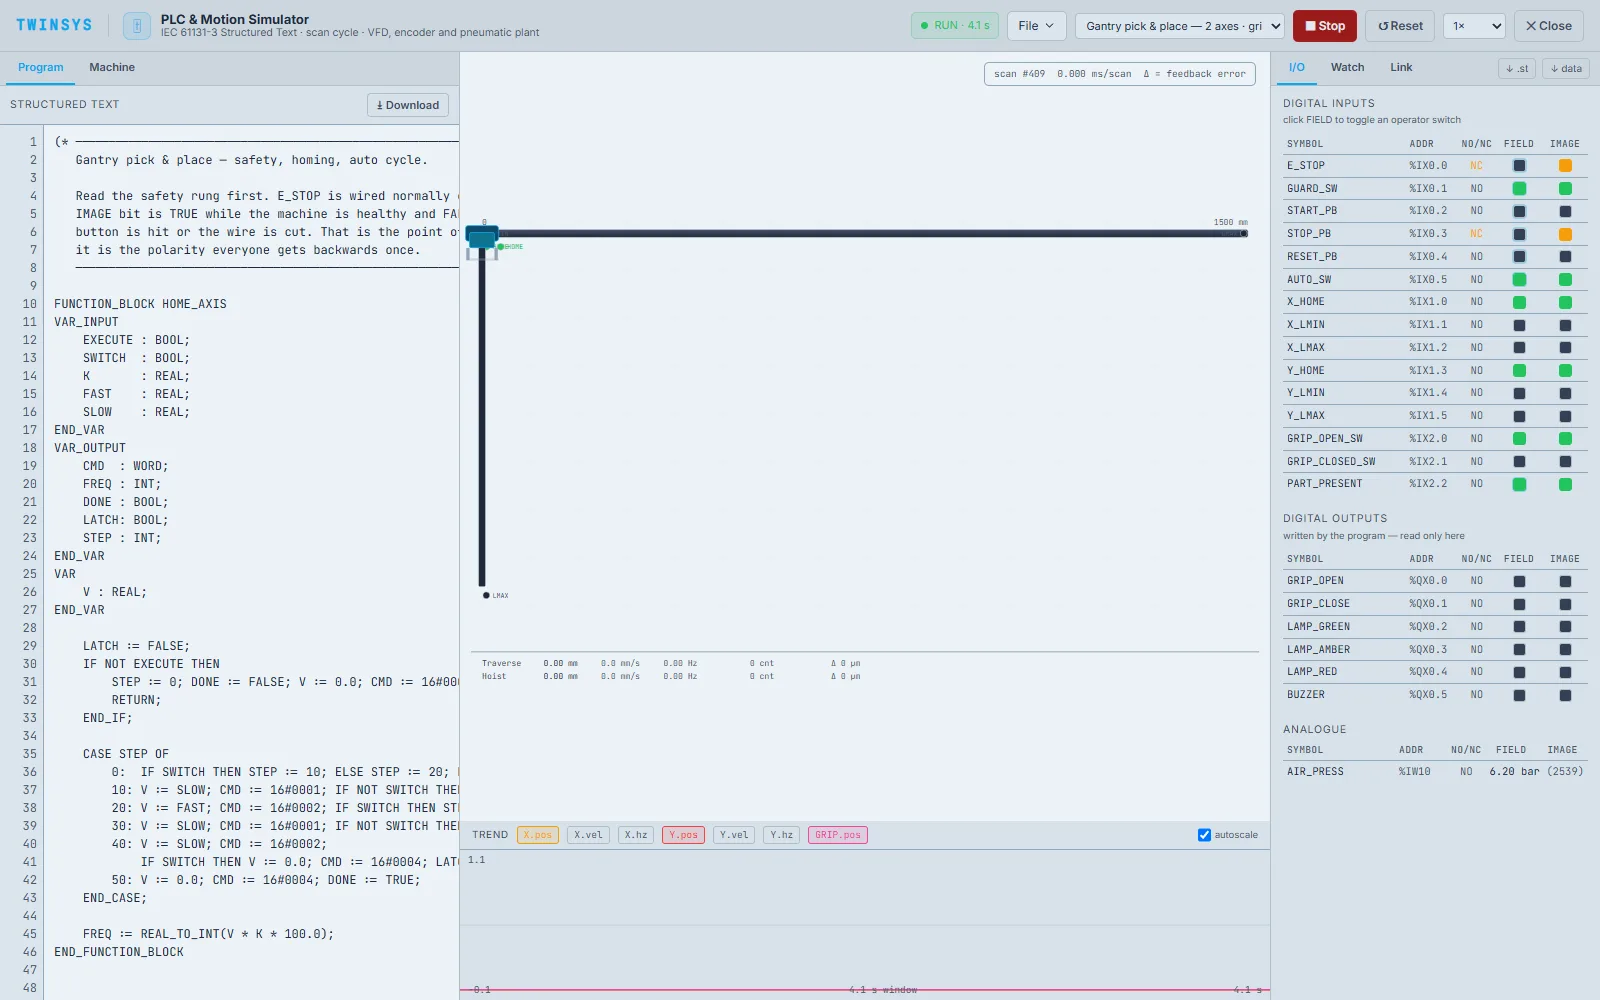
Highlights
- Process image sampled once per scan, encoder feedback in whole pulses, drives that ramp
- Plant models for VFD motors, incremental encoders, limit switches and pneumatic actuators
- Three generic machines to start from: gantry pick-and-place, single-axis positioner, transfer cell
- Live I/O table with field and image states, watch and trend, and program-vs-machine position
- Link a real PLC over Modbus TCP via the Twinsys Host; I/O list and drivetrain datasheet exports
A question it answers
Will this homing routine and pick-and-place sequence actually work on the machine, and how repeatable will my home position be?What you put in
A machine definition — axes with drivetrain (motor, gearbox, pinion or screw), encoder resolution and mounting point, limit and home switches, pneumatic actuators, and named I/O points — plus a Structured Text program. Three generic machines are supplied as starting points: a two-axis gantry with gripper and safety chain, a single-axis positioner, and a three-axis transfer cell; or, in place of the program, a real PLC linked over Modbus TCP through the Twinsys Host (Twinsys as server or client, register blocks, 32-bit word order).
What you get
Live I/O table showing FIELD state and IMAGE state separately; watch and trend of any symbol; machine viewport with a delta column comparing where the machine actually is against where the program believes it is; cycle timing; derived drivetrain quantities shown next to the inputs they come from (counts per millimetre, resolution, speed at maximum frequency, drive acceleration ceiling, creep distance per scan); and export of the I/O list as CSV and a drivetrain datasheet, both generated from the model; and, while a PLC is linked, the full Modbus register map with a CSV download.
More in this family
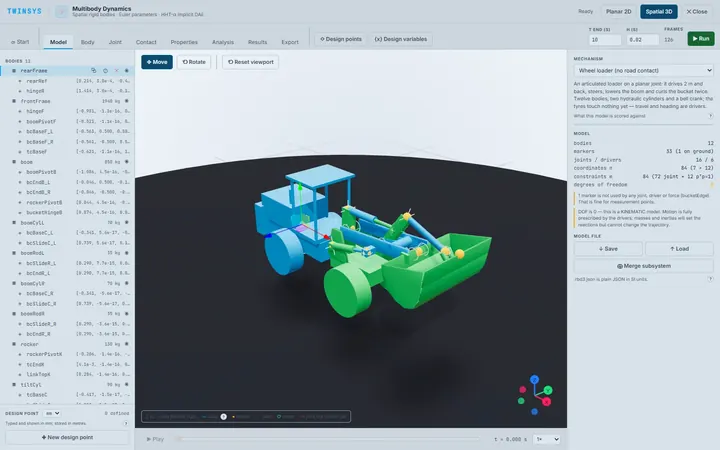
Multibody Dynamics
PremiumRigid-body mechanism dynamics in 2D and 3D: joints, drivers, springs, bushings and contact, with the reaction at every joint.
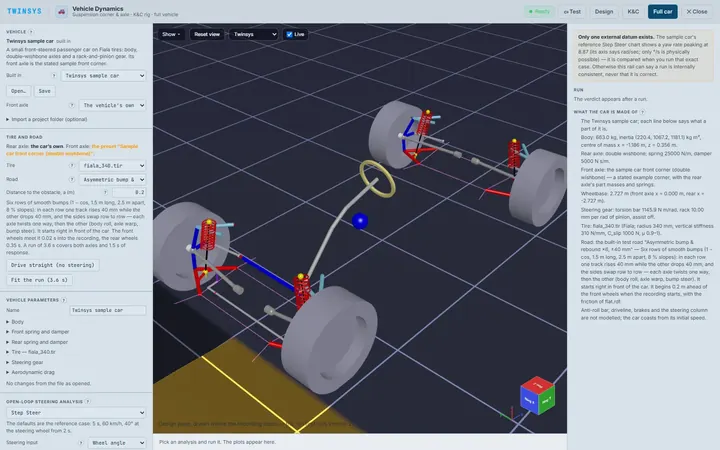
Vehicle Dynamics
Free accountBuild a suspension corner from hardpoints, run kinematics and compliance sweeps, and drive a full vehicle over test roads in 3D.
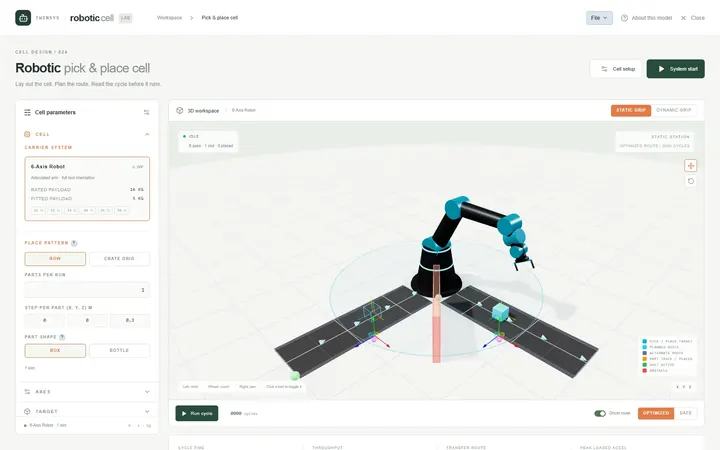
Robotic Cell
PremiumLay out a pick-and-place cell for a palletiser, six-axis arm, SCARA or gantry, plan a collision-free route and get the cycle time.