Multibody Dynamics
Rigid-body mechanism dynamics in 2D and 3D: joints, drivers, springs, bushings and contact, with the reaction at every joint.
Product pages are in English.
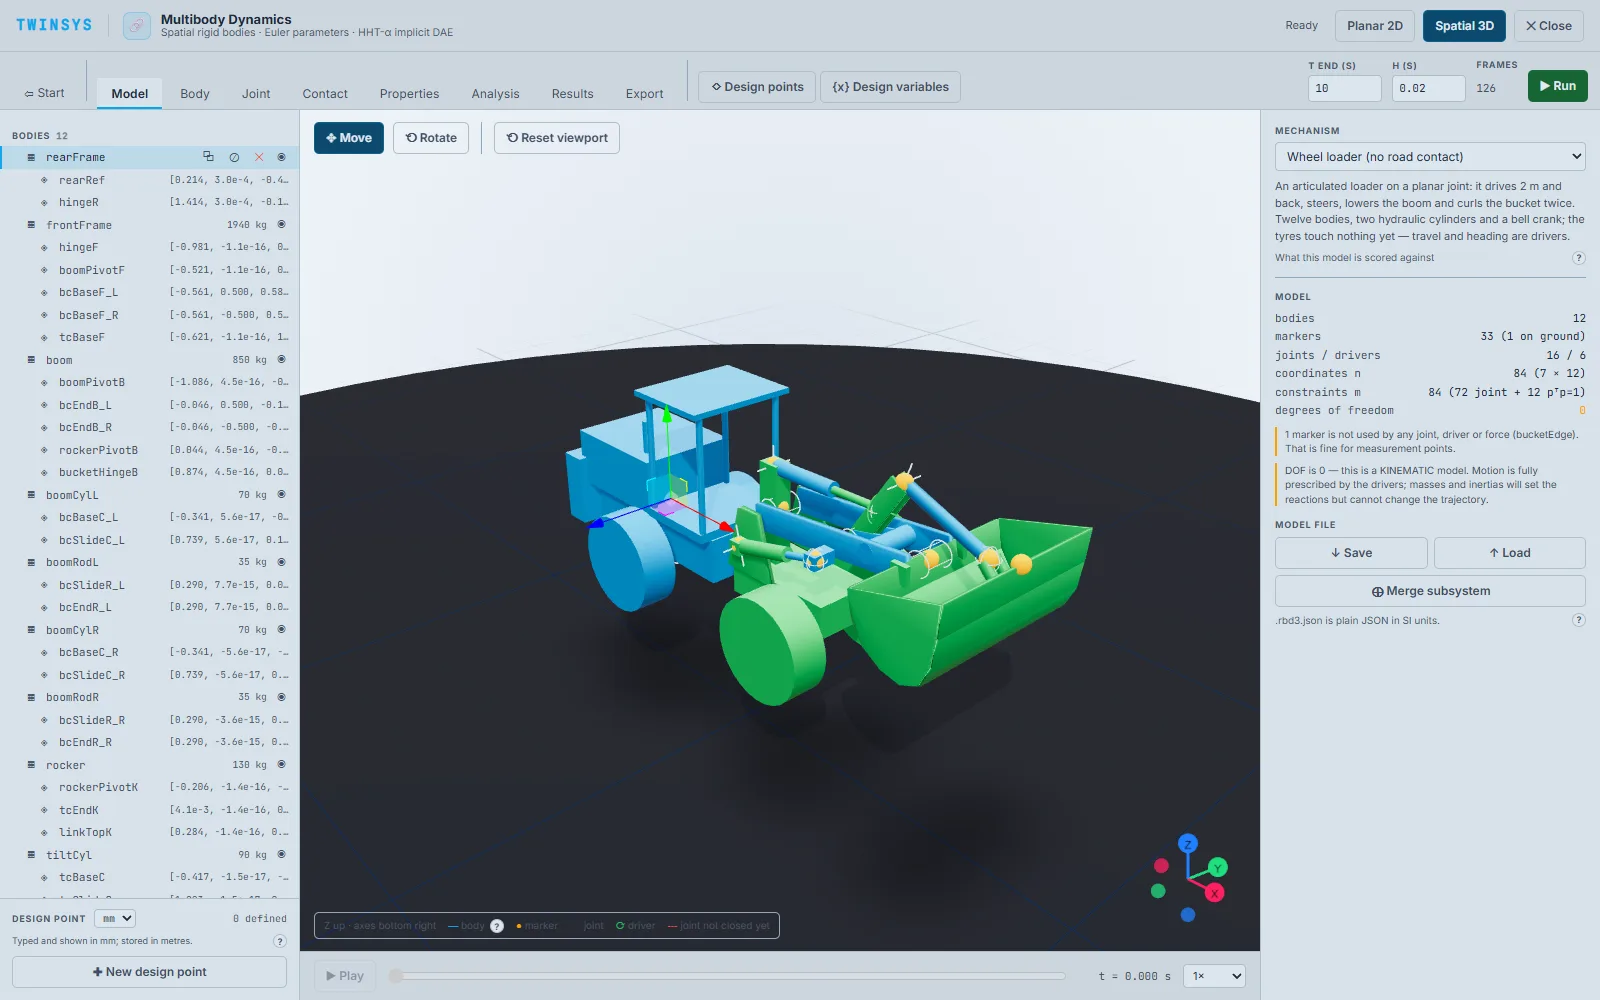
Highlights
- Revolute, translational, cylindrical, spherical, universal, fixed, CV, inline and planar joints
- Bodies from typed mass properties, geometry primitives or an imported STEP solid
- 3D contact pairs with stiffness, damping and separate static and dynamic friction
- Joint reaction forces and moments, energy and constraint checks, and a plain-language verdict
- Send a mechanism to the simulation canvas as a live block or a one-coordinate inertia model
A question it answers
What torque does the drive need over one cycle of this linkage, and what reaction forces do the crank pin bearings actually see?What you put in
Bodies with mass and inertia — entered directly, derived from a geometry primitive, or measured from an imported STEP solid; markers; joints (revolute, translational, cylindrical, spherical, universal, fixed and constant-velocity); motion drivers; springs, dampers and six-component bushings; contact pairs with a stiffness, force exponent, damping, penetration depth and separate static and dynamic friction coefficients; gravity; time span and step size; and optional design points and design variables whose coordinates can be expressions. Models save and load as files; a length unit is declared per model.
What you get
Time histories of position, velocity and acceleration at any marker; joint reaction forces and moments; constraint violation and energy drift diagnostics; a plain-language verdict on whether the run can be trusted; animated 3D viewport with joint symbols and an orientation gizmo; a model tree with duplicate, delete and suppress; and export of a one-degree-of-freedom mechanism to the canvas as a position-dependent equivalent inertia, torque and damping table.
More in this family
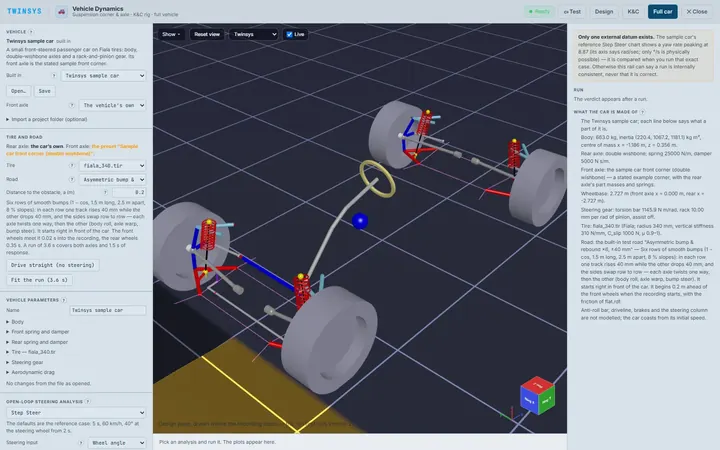
Vehicle Dynamics
Free accountBuild a suspension corner from hardpoints, run kinematics and compliance sweeps, and drive a full vehicle over test roads in 3D.
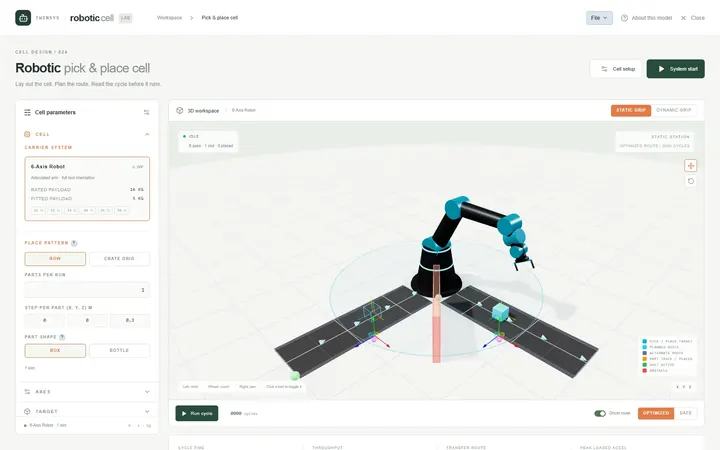
Robotic Cell
PremiumLay out a pick-and-place cell for a palletiser, six-axis arm, SCARA or gantry, plan a collision-free route and get the cycle time.
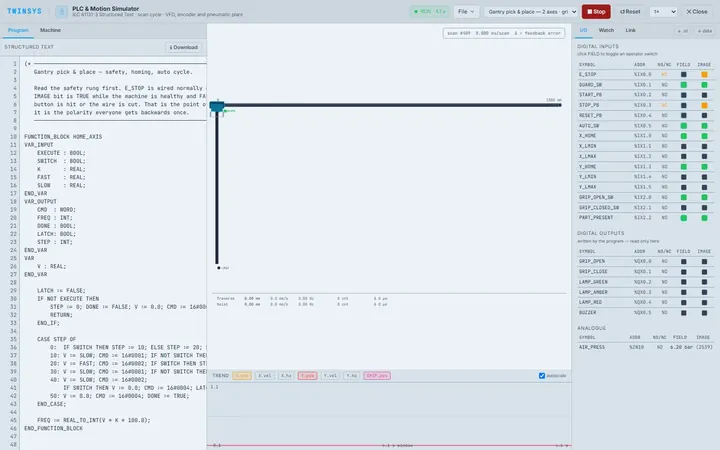
PLC & Motion Simulator
PremiumTest control logic on a simulated machine before it reaches hardware: Structured Text on a real scan cycle, or your PLC over Modbus TCP.