Robotic Cell
pick and place
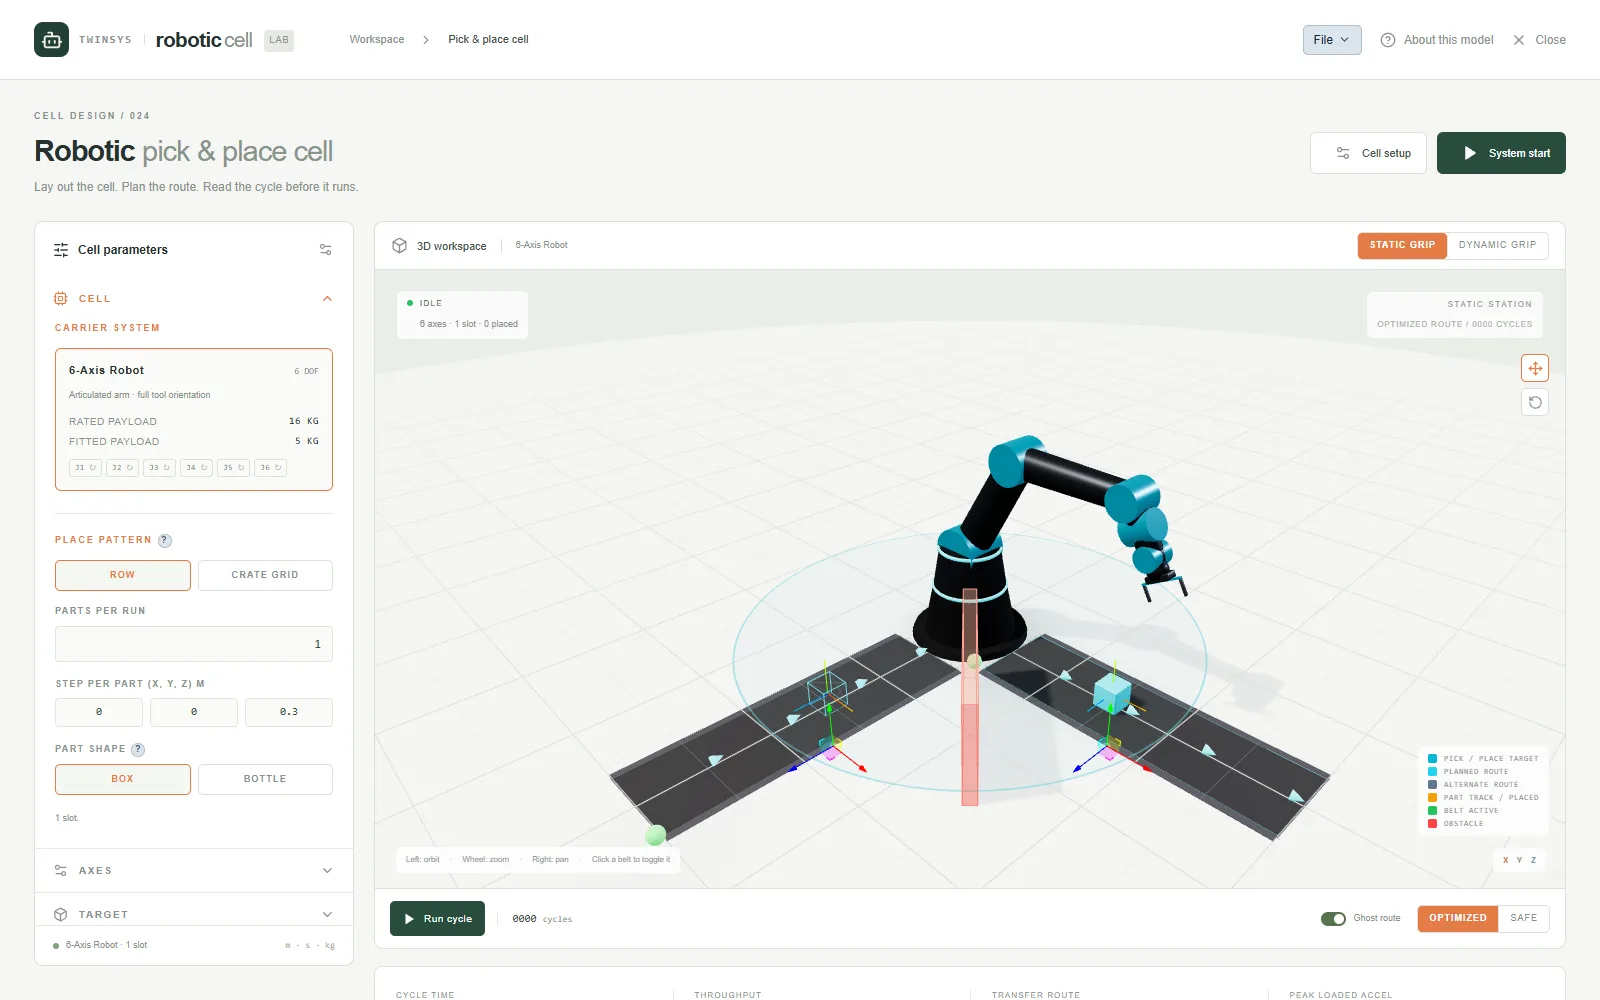
Lay out a pick-and-place cell for a palletiser, six-axis arm, SCARA or gantry, plan a collision-free route and get the cycle time.
Product pages are in English.
Highlights
- Checks at setup whether the chosen robot can reach every pick and place target
- Plans collision-free routes around obstacles and conveyors, drawn beside a reference path
- Cycle time and parts per hour, with the fixed dwell share broken out separately
- Gripper or vacuum holding force checked at the route's peak acceleration
- Conveyor tracking shows whether the robot keeps up with the line or misses parts
A question it answers
Can a SCARA reach this step-down placement, and if I run the infeed belt at 0.5 m/s will the robot keep up or start missing parts?What you put in
Carrier and scenario selection, cell dimensions, axis limits or gantry envelope, pick and place targets, tool type and parameters (clamp force and friction for a gripper; cup count, area and vacuum level for a suction tool), payload mass, route mode, belt speeds and part pitch, and the place pattern (single row or crate grid) with part shape.
What you get
Animated 3D cell, both the reference and the optimised route drawn together with the distance saving stated, a reach-envelope floor decal evaluated at place height, cycle time and parts per hour with the fixed-dwell share broken out separately, static and dynamic holding-force checks at the route's peak acceleration, a line-versus-robot bottleneck card with the missed-part fraction and idle time, and crate fill time with crates per hour.
More in this family
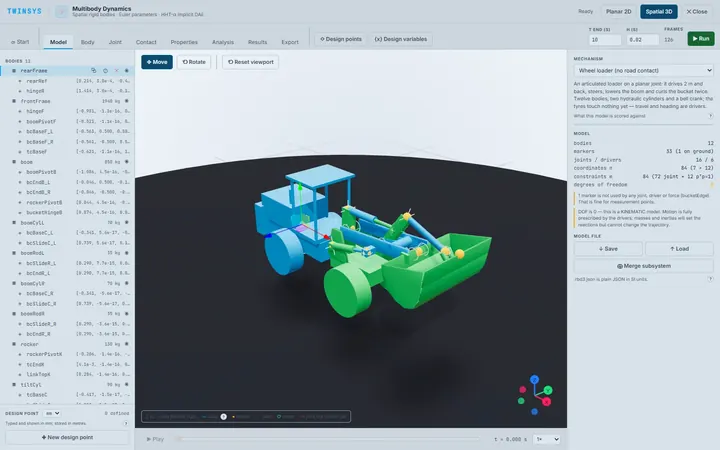
Multibody Dynamics
PremiumRigid-body mechanism dynamics in 2D and 3D: joints, drivers, springs, bushings and contact, with the reaction at every joint.
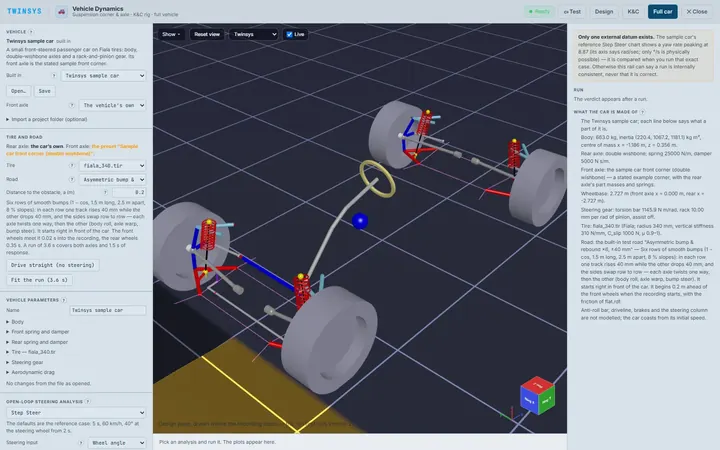
Vehicle Dynamics
Free accountBuild a suspension corner from hardpoints, run kinematics and compliance sweeps, and drive a full vehicle over test roads in 3D.
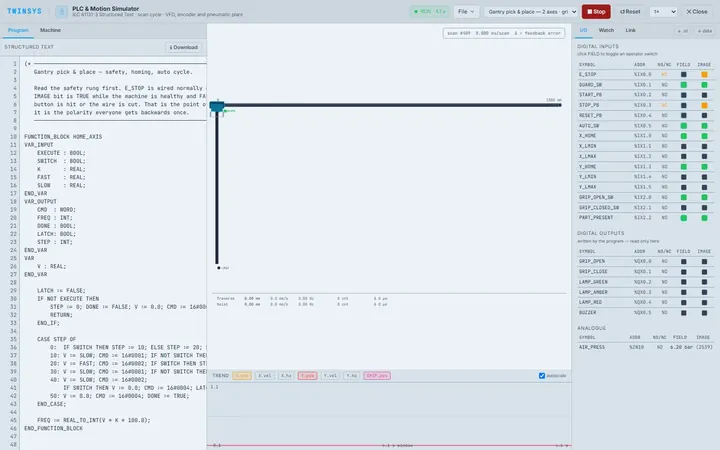
PLC & Motion Simulator
PremiumTest control logic on a simulated machine before it reaches hardware: Structured Text on a real scan cycle, or your PLC over Modbus TCP.